How far off is the drone after GPS is lost?
On the same test flight, 5 minutes after GPS was jammed: the autopilot alone was 2,366 m off, Pathfinder was 85 m off (simulator, 1 flight, run twice).
Across 8 test flights, the autopilot alone is typically about 3.9 km off after 5 minutes. Over 24 flights, Pathfinder (physics only) is typically 20 m off; that row is in the table below.
Simulator results, not a real aircraftPages: Jury deck · Results explorer (deck slide 26) · Flight simulator · Results · Demo · Start here · How we test · Index · 14 Oct day summary
Results at a glance (measured (sim))
Pathfinder means physics only: jam detection, drag model and learned wind, the best system measured so far. The speed AI is the learning part; it joins the headline only once it beats physics only (D-N3-LEAD-1).
| Result | Number | Detail |
|---|---|---|
| Pathfinder (physics only) vs ArduPilot alone | 3.37 % vs 84.8 % | error as % of distance flown, at 10 km; 59 flights; benchmark still running. Pathfinder + speed AI v3: 4.72 % (59 flights); with the quad speed AI: not flown yet |
| Error 1, 2, 5 min after the jam | 5.5 / 3.1 / 5.8 m | median, 60 flights, 18 reach 5 min; ArduPilot alone 550 / 1,152 / 2,986 m |
| Speed AI, the learning part | 11 % lower error | quadcopter speed AI vs mixed-airframe speed AI: 403 vs 455 m median error 2 min after the jam, speed AI alone (offline), 8 held-out flights; flying in the benchmark now |
| Jam and spoof detection | 31 of 31 spoofs caught | slowest 2.25 s, limit 5 s; jam: 20 of 24 jammed missions kept flying (pass mark 23); false-alarm rate not measured yet |
| Image place recognition, prototype | 2.0 m median fix error | p95 4.8 m, 96 synthetic frames, local search |
| Demo routes | 7 routes, 7 recorded | recordings flown with Pathfinder + speed AI v3; live flights default to Pathfinder (physics only) |
How far off, minute by minute
The gap between where the drone thinks it is and where it really is, counted from the moment GPS was jammed. Smaller is better.
| What was tested | After 1 min | After 2 min | After 5 min | Per minute |
|---|---|---|---|---|
| Autopilot aloneWhat a normal drone does today (ArduPilot).Measured (sim): typical result of 8 test flights. | 1,443 m | 2,059 m | 3,852 m | 770 m |
| Our speed model aloneA trained model that guesses the drone's speed from its own sensors.Measured (sim): typical result of the same 8 test flights. | 305 m | 547 m | 1,541 m | 308 m |
| Pathfinder (physics + speed AI)Jam detection, drag model, learned wind, plus a neural-network speed estimate, steering the autopilot.Measured (sim). The autopilot was flown on the very same flight. The headline now quotes Pathfinder (physics only), the best measured system (D-N3-LEAD-1).One test flight, run twice. Same result both times. | 3 m | 5 m | 85 m | 17 m |
| Pathfinder (physics only)Jam detection, drag model and learned wind, no AI, steering the autopilot. The best measured system.Measured (sim): typical result of 24 flights in the simulator, 13 Oct. | 3 m | 4 m | 20 m | 4 m |
| Pathfinder (physics + drift-correcting AI)Measured (sim): typical result of 24 flights in the simulator, 13 Oct, with the AI steering the drone; all 24 reached 5 min. About 6x worse than physics only at 2 min. Off by default.Estimate from replaying recorded data, not flown: 47.5 m at 2 min vs 78.4 m for physics only. That win did not carry over to real flying in the simulator. | 11 m | 25 m | 105 m | 21 m |
| Pathfinder (physics + speed AI + drift-correcting AI)Measured (sim): typical result of 24 flights in the simulator, 13 Oct, with the AI steering the drone; all 24 reached 5 min. Also about 6x worse than physics only at 2 min (4 m). Off by default.Offline estimate: not replayed offline. | 13 m | 24 m | 103 m | 21 m |
- "Typical" means the middle result: half the 8 flights did better, half did worse.
- On Pathfinder's test flight, the autopilot alone was 866 m off after 1 minute, 1,234 m after 2 and 2,366 m after 5.
- "Per minute" is the 5-minute figure divided by 5. The drift is not steady, so treat it as a rough average.
- The two drift-correcting AI rows were measured in the simulator, 24 flights each, on 13 Oct. The AI's drift correction feeds the filter, and the filter feeds the AI's next window, so its errors compound in flight; the offline replay could not show that. Report: proof Q3.
The two flown Pathfinder systems, as formulas
- \hat p where Pathfinder thinks the drone is
- v speed and direction over the ground
- u speed through the air, along the drone's own axes
- w the wind, learned while GPS was good
- C(q) the drone's tilt and heading (turns body axes into north-east-down)
- \bar f_{xy} forward and sideways push the accelerometer feels; thrust only pushes up the body, so this is air drag
- k,\;k_q drag coefficients fitted to the quad (linear and squared)
- d how many standard deviations a GPS fix sits from the estimate
- z_{\text{AI}} the network's speed-through-the-air estimate
- \nu its error, assumed random
- R_{\text{AI}} how noisy the filter assumes it is: 4.8 m/s, counted as one reading per 29.4 s
- Read from crates/pathfinder-core: eskf.rs:136-167, drag.rs:6-82, integrity.rs:166-181, learned.rs:290-327. Full derivation: docs/pitch/how-it-works.html slides 8-10.
The same numbers, drawn
Each gridline is ten times the one before. A bar one gridline shorter means ten times closer to the truth.
Night 3: quad results (measured (sim))
Generated from docs/night/*.json by docs/pitch/build_night3.py; a pending row has no result yet.
| Result | Status | Numbers |
|---|---|---|
| Results at a glance | ready | Pathfinder (physics only) vs ArduPilot alone: 3.37 % vs 84.8 % | Error 1, 2, 5 min after the jam: 5.5 / 3.1 / 5.8 m | Speed AI, the learning part: 11 % lower error | Jam and spoof detection: 31 of 31 spoofs caught | Image place recognition, prototype: 2.0 m median fix error | Demo routes: 7 routes, 7 recorded |
| Jam and spoof detection: results | ready | 31 of 31 spoofs caught within 2.25 s (limit 5 s), slowest switch 2.75 s; false alarms not measured; 5 re-trusts, fixed, not re-flown |
| Master one airframe first | ready | r1-quad341-vs-mixed: mixed 455.1 m vs quad 537.0 m, mixed wins; r2-quad-manifest-vs-mixed: mixed 455.1 m vs quad-manifest 403.2 m, quad-manifest wins; r3-quad-manifest-wd-vs-quad-manifest: quad-manifest 403.2 m vs quad-manifest-wd 413.2 m, quad-manifest wins; r4-quad-all-vs-quad-manifest: quad-manifest 403.2 m vs quad-all 421.5 m, quad-manifest wins; r4-quad-all-vs-quad-manifest-4seeds: quad-manifest 403.2 m vs quad-all 426.5 m, quad-manifest wins (t+120 s, 8 held-out) |
| Quad error every 30 s after the jam | ready | ArduPilot alone: 30 s 237.1 m, 60 s 549.7 m, 90 s 859.2 m, 120 s 1152.2 m, 150 s 1439.2 m, 180 s 1775.7 m, 210 s 2087.0 m, 240 s 2305.6 m, 270 s 2610.8 m, 300 s 2985.7 m; Pathfinder (physics only): 30 s 4.0 m, 60 s 5.5 m, 90 s 3.0 m, 120 s 3.1 m, 150 s 3.6 m, 180 s 4.6 m, 210 s 5.4 m, 240 s 8.0 m, 270 s 6.7 m, 300 s 5.8 m; Pathfinder (physics + speed AI) (velocity-v3): 30 s 3.9 m, 60 s 5.0 m, 90 s 2.7 m, 120 s 3.0 m, 150 s 3.4 m, 180 s 4.2 m, 210 s 4.8 m, 240 s 6.6 m, 270 s 3.1 m, 300 s 3.5 m; Pathfinder (physics + drift-correcting AI): 30 s 14.6 m, 60 s 31.5 m, 90 s 30.6 m, 120 s 41.5 m, 150 s 55.4 m, 180 s 70.0 m, 210 s 89.6 m, 240 s 115.0 m, 270 s 137.0 m, 300 s 155.9 m; Pathfinder (physics + speed AI + drift-correcting AI) (velocity-v3): 30 s not flown yet, 60 s not flown yet, 90 s not flown yet, 120 s not flown yet, 150 s not flown yet, 180 s not flown yet, 210 s not flown yet, 240 s not flown yet, 270 s not flown yet, 300 s not flown yet; Pathfinder (physics + drift-correcting AI, gated): 30 s not flown yet, 60 s not flown yet, 90 s not flown yet, 120 s not flown yet, 150 s not flown yet, 180 s not flown yet, 210 s not flown yet, 240 s not flown yet, 270 s not flown yet, 300 s not flown yet; Pathfinder (physics + terrain matching): 30 s not flown yet, 60 s not flown yet, 90 s not flown yet, 120 s not flown yet, 150 s not flown yet, 180 s not flown yet, 210 s not flown yet, 240 s not flown yet, 270 s not flown yet, 300 s not flown yet; Pathfinder (physics + speed AI) (velocity-quad-night3): 30 s 3.9 m, 60 s 5.5 m, 90 s 2.8 m, 120 s 2.8 m, 150 s 3.6 m, 180 s 4.1 m, 210 s 4.5 m, 240 s 6.0 m, 270 s 6.7 m, 300 s 6.1 m; Pathfinder (physics + speed AI + drift-correcting AI) (velocity-quad-night3): 30 s not flown yet, 60 s not flown yet, 90 s not flown yet, 120 s not flown yet, 150 s not flown yet, 180 s not flown yet, 210 s not flown yet, 240 s not flown yet, 270 s not flown yet, 300 s not flown yet |
| Quad benchmark: error as % of distance | partial | partial: 297 of 540 flights, at 14:05. Pending (not flown yet): Pathfinder (physics + terrain matching), Pathfinder (physics + speed AI + drift-correcting AI) (velocity-quad-night3). ArduPilot alone: 0.5 km 86.5 %, 1.0 km 92.8 %, 1.5 km 94.4 %, 2.0 km 95.0 %, 2.5 km 95.2 %, 3.0 km 95.3 %, 3.5 km 94.5 %, 4.0 km 94.0 %, 4.5 km 93.4 %, 5.0 km 91.9 %, 5.5 km 90.8 %, 6.0 km 89.7 %, 6.5 km 89.7 %, 7.0 km 87.3 %, 7.5 km 87.0 %, 8.0 km 86.8 %, 8.5 km 86.5 %, 9.0 km 85.6 %, 9.5 km 85.4 %, 10.0 km 84.8 %; Pathfinder (physics only): 0.5 km 2.9 %, 1.0 km 2.8 %, 1.5 km 2.7 %, 2.0 km 2.7 %, 2.5 km 3.2 %, 3.0 km 3.1 %, 3.5 km 3.3 %, 4.0 km 3.1 %, 4.5 km 3.1 %, 5.0 km 3.1 %, 5.5 km 3.1 %, 6.0 km 3.4 %, 6.5 km 3.1 %, 7.0 km 3.1 %, 7.5 km 3.1 %, 8.0 km 3.2 %, 8.5 km 3.2 %, 9.0 km 3.2 %, 9.5 km 3.1 %, 10.0 km 3.4 %; Pathfinder (physics + speed AI) (velocity-v3): 0.5 km 2.7 %, 1.0 km 2.5 %, 1.5 km 2.5 %, 2.0 km 2.6 %, 2.5 km 3.2 %, 3.0 km 3.2 %, 3.5 km 3.4 %, 4.0 km 3.2 %, 4.5 km 3.3 %, 5.0 km 3.4 %, 5.5 km 3.5 %, 6.0 km 3.5 %, 6.5 km 3.3 %, 7.0 km 3.6 %, 7.5 km 3.6 %, 8.0 km 3.5 %, 8.5 km 3.5 %, 9.0 km 3.5 %, 9.5 km 3.9 %, 10.0 km 4.7 %; Pathfinder (physics + drift-correcting AI): 0.5 km 6.6 %, 1.0 km 7.1 %, 1.5 km 7.2 %, 2.0 km 6.8 %, 2.5 km 7.5 %, 3.0 km 7.1 %, 3.5 km 7.9 %, 4.0 km 8.6 %, 4.5 km 8.6 %, 5.0 km 9.2 %, 5.5 km 10.6 %, 6.0 km 11.2 %, 6.5 km 11.8 %, 7.0 km 11.8 %, 7.5 km 11.4 %, 8.0 km 10.9 %, 8.5 km 10.3 %, 9.0 km 10.0 %, 9.5 km 9.8 %, 10.0 km 11.9 %; Pathfinder (physics + speed AI + drift-correcting AI) (velocity-v3): 0.5 km 7.3 %, 1.0 km 7.5 %, 1.5 km 7.7 %, 2.0 km 8.5 %, 2.5 km 8.7 %, 3.0 km 8.2 %, 3.5 km 8.7 %, 4.0 km 9.2 %, 4.5 km 9.8 %, 5.0 km 10.4 %, 5.5 km 11.1 %, 6.0 km 11.8 %, 6.5 km 12.6 %, 7.0 km 16.0 %, 7.5 km 16.4 %, 8.0 km 17.0 %, 8.5 km 17.4 %, 9.0 km 17.8 %, 9.5 km 18.2 %, 10.0 km 18.6 %; Pathfinder (physics + drift-correcting AI, gated): 0.5 km 7.8 %, 1.0 km 9.0 %, 1.5 km 10.0 %, 2.0 km 10.7 %, 2.5 km 11.0 %, 3.0 km 11.2 %, 3.5 km 11.4 %, 4.0 km 11.6 %, 4.5 km 11.8 %, 5.0 km 11.9 %, 5.5 km 12.2 %, 6.0 km 12.5 %, 6.5 km 12.9 %, 7.0 km 12.3 %, 7.5 km 12.6 %, 8.0 km 13.1 %, 8.5 km 13.8 %, 9.0 km 14.3 %, 9.5 km 14.7 %, 10.0 km 14.8 %; Pathfinder (physics + speed AI) (velocity-quad-night3): 0.5 km 2.7 %, 1.0 km 2.6 %, 1.5 km 3.0 %, 2.0 km 3.0 %, 2.5 km 3.3 %, 3.0 km 3.2 %, 3.5 km 3.3 %, 4.0 km 3.3 %, 4.5 km 3.3 %, 5.0 km 3.3 %, 5.5 km 3.7 %, 6.0 km 4.6 %, 6.5 km not flown yet, 7.0 km not flown yet, 7.5 km not flown yet, 8.0 km not flown yet, 8.5 km not flown yet, 9.0 km not flown yet, 9.5 km not flown yet, 10.0 km not flown yet; pending (not flown yet): Pathfinder (physics + terrain matching), Pathfinder (physics + speed AI + drift-correcting AI) (velocity-quad-night3) |
| Quad-only model vs mixed-airframe model | ready | r1-quad341-vs-mixed: mixed 455.1 m vs quad 537.0 m, mixed wins; r2-quad-manifest-vs-mixed: mixed 455.1 m vs quad-manifest 403.2 m, quad-manifest wins; r3-quad-manifest-wd-vs-quad-manifest: quad-manifest 403.2 m vs quad-manifest-wd 413.2 m, quad-manifest wins; r4-quad-all-vs-quad-manifest: quad-manifest 403.2 m vs quad-all 421.5 m, quad-manifest wins; r4-quad-all-vs-quad-manifest-4seeds: quad-manifest 403.2 m vs quad-all 426.5 m, quad-manifest wins (t+120 s, 8 held-out) |
| Image place recognition, prototype | ready | fix error median 2.0 m, p95 4.8 m, match rate 100.0 %, 96 queries; tiles: CC BY 4.0 (Contains modified Copernicus Sentinel data 2016); Sentinel-2 cloudless 2016 by EOX IT Services GmbH (s2maps.eu), WMTS layer s2cloudless_3857 |
| Terrain matching, second try | ready | route 1010 t+60 s: terrain off 6.0 vs experimental-terrain 5.1 m; route 1010 t+120 s: terrain off 12.3 vs experimental-terrain 11.1 m; route 1010 t+300 s: terrain off 175.1 vs experimental-terrain 168.1 m; route 1011 t+60 s: terrain off 1.5 vs experimental-terrain 1.1 m; route 1011 t+120 s: terrain off 2.4 vs experimental-terrain 2.1 m; route 1011 t+300 s: terrain off 18.7 vs experimental-terrain 308.8 m; route 1012 t+60 s: terrain off 1.7 vs experimental-terrain 2.8 m; route 1012 t+120 s: terrain off 2.4 vs experimental-terrain 3.4 m; route 1012 t+300 s: terrain off 6.9 vs experimental-terrain 187.7 m |
| Hexa and octa: fine-tuned vs mixed | ready | hexa t+60 s: mixed v3 (all frames) 283.2 vs fine-tuned per frame (median of seeds) 283.2 m; hexa t+120 s: mixed v3 (all frames) 496.8 vs fine-tuned per frame (median of seeds) 496.8 m; hexa t+300 s: mixed v3 (all frames) 1293.5 vs fine-tuned per frame (median of seeds) 1293.5 m; octa t+60 s: mixed v3 (all frames) 334.4 vs fine-tuned per frame (median of seeds) 334.4 m; octa t+120 s: mixed v3 (all frames) 630.8 vs fine-tuned per frame (median of seeds) 630.8 m; octa t+300 s: mixed v3 (all frames) 1656.3 vs fine-tuned per frame (median of seeds) 1656.3 m |
| Learning in flight while GPS is good | ready | heldout-jam-1000: best 2.1 vs experimental-inflight-adapt 1.9 m; heldout-jam-1003: best 2.6 vs experimental-inflight-adapt 3.6 m; heldout-jam-1006: best 2.2 vs experimental-inflight-adapt 2.1 m; heldout-jam-1009: best 8.6 vs experimental-inflight-adapt 8.3 m; heldout-jam-1012: best 3.0 vs experimental-inflight-adapt 4.3 m; heldout-jam-1015: best 6.3 vs experimental-inflight-adapt 6.0 m; heldout-jam-1018: best 2.2 vs experimental-inflight-adapt 2.8 m; heldout-jam-1021: best 2.7 vs experimental-inflight-adapt 3.0 m |
| What we tried that lost | ready | Quad round r1-quad341-vs-mixed: 455.1 vs 537.0 m; Quad round r3-quad-manifest-wd-vs-quad-manifest: 403.2 vs 413.2 m; Quad round r4-quad-all-vs-quad-manifest: 403.2 vs 421.5 m; Quad round r4-quad-all-vs-quad-manifest-4seeds: 403.2 vs 426.5 m; Terrain matching, second try (sigma-ratio-4 gate) (t+300 s): 18.7 vs 187.7 m; Hexa and octa: fine-tuned vs mixed: 563.8 vs 563.8 m; Learning in flight while GPS is good (quad, t+120 s, flown): 2.6 vs 3.3 m; Speed AI round 4 (997 flights): 403.2 vs 421.5 m; Speed-scale calibration (2 cycles): 77.7 vs 77.7 m; Last-layer tune per flight, flown: 2.45 vs 3.32 m |
Where the drift comes from
Wind and drag cause most drift; heading barely matters. Each physics-only flight's drift, split by source, over 64 replays. measured (sim)
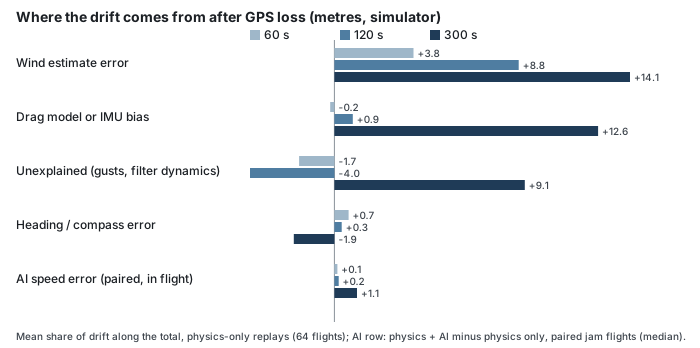
Tap the chart to open it full size.
| Source, ranked | After 1 min | After 2 min | After 5 min |
|---|---|---|---|
| 1. Wind estimate error | 3.8 m | 8.8 m | 14.1 m |
| 2. Drag coefficient, mass or accelerometer bias (one item) | -0.2 m | 0.9 m | 12.6 m |
| 3. Unexplained | -1.7 m | -4.0 m | 9.1 m |
| 4. Speed AI error | 0.14 m | 0.20 m | 1.07 m |
| 5. Heading | 0.7 m | 0.3 m | -1.9 m |
| Median total | 2.0 m | 4.9 m | 18.6 m |
- Wind plus drag or bias explain about 27 of the 34 m mean drift at 5 minutes.
- Wind numbers are a fit estimate. A negative share means that source pulled the estimate back toward the truth.
- Source: docs/night/2026-10-13-error-budget.svg · tool from fb9a2ae ACC-STEP-1 "Error budget: which source causes the drift".
Progress, day by day
Every milestone from 11 to 13 October, with the losses left in. Each number says how it was measured.
| Milestone | Number | Kind |
|---|---|---|
| 11 October 00:58 Core passes on Linux, ARM, Windows | AC-08 green | measured (code tests) |
| 11 October 01:59 First jammed flights in the simulator | built | |
| 11 October 02:24 Same answer on every replay | AC-09: 1,463 rows identical | measured (code tests) |
| 11 October 12:46 Runaway found and fixed | 3,135 to 29.6 m at 5 min | measured (sim) |
| 12 October Proof flight, flown twice | 85 m vs ArduPilot 2,366 m | measured (sim) |
| 12 October Fake GPS caught, 31 of 31 | flagged in 0.09-2.25 s | measured (sim) |
| 12 October Mission test after fixes | AC-01: 11 to 20 of 24 | measured (sim) |
| 13 October 00:13 All four acceptance tests in one run | 1,086 s; AC-04 passes | measured (sim) |
| 13 October 01:28 Drift ranked by source | wind first: 14.1 m at 5 min | measured (sim) |
| 13 October 02:16 Re-flown fixes, one flight | 132 to 15 m at 5 min | measured (sim) |
| 13 October 15:05 Model 2 flown in the loop | lost: 24.59 vs 3.99 m | measured (sim) |
| 13 October 16:25 Replay: every system on one map | built | |
| 13 October 18:12 Terrain matching, offline | 200.4 to 128.1 m at 5 min | offline estimate |
| 13 October 18:32 One branch, 11 presets | built | |
| 13 October 18:32 Terrain in the loop, 1 flight | lost: 333.7 vs 172.6 m | measured (sim) |
| 13 October 19:37 Control Room: New run in 5 steps | built | |
| 13 October 19:46 Drift-AI gate, replayed | lost: 3.30 vs 3.11 m | measured (sim) |
Every try, against Pathfinder (physics only)
Same flights, physics only as the reference. Most tries lost; each sits behind an off switch, so the default did not change.
| Try | Try | Physics only | Kind | Result |
|---|---|---|---|---|
| Speed AI, fast run 2 (1 min) | 1.97 m | 2.14 m | measured (sim) | won |
| Speed AI, fast run 2 (2 min) | 3.71 m | 3.31 m | measured (sim) | lost |
| Q1 radius + adapter fix (2 min) | 3.46 m | 2.75 m | measured (sim) | lost |
| Q1 radius + adapter fix (5 min) | 17.59 m | 18.78 m | measured (sim) | won |
| Q2 touchdown clamp (2 min) | 3.66 m | 3.35 m | measured (sim) | lost |
| Drag learning in flight (2 min) | 159.6 m | 80.4 m | measured (sim) | lost |
| Model 2 drift AI, offline (2 min) | 47.5 m | 78.4 m | offline estimate | won |
| Model 2 drift AI, Q3 in loop (2 min) | 24.59 m | 3.99 m | measured (sim) | lost |
| Drift-AI gate, best, replay (2 min) | 3.3 m | 3.11 m | measured (sim) | lost |
| Terrain fixes, offline (5 min) | 128.1 m | 200.4 m | offline estimate | won |
| Terrain fixes, in the loop (5 min) | 333.7 m | 172.6 m | measured (sim) | lost |
- Terrain matching, offline (12 held-out flights, synthetic rangefinder): physics only 33.0 / 73.7 / 200.4 m, with terrain 33.0 / 73.7 / 128.1 m at 1 / 2 / 5 min; 0 false fixes after the guards. One SITL flight over real terrain, replayed: 247.8 to 155.5 m at 5 min. Same flight live in the loop: 172.6 to 333.7 m, 2 fixes, both hurt; likely cause, untested: SITL ground on a 100 m grid vs a 30 m SRTM tile. terrain-offline.md
- Drift-AI gate, replay of 24 Q3 logs at 1 / 2 / 5 min: physics only 1.26 / 3.11 / 23.09 m, shipped aid 1.54 / 5.39 / 32.03 m, best gate 1.41 / 3.30 / 27.21 m. No gate beats physics only. drift-gate-replay.md
- Q1 to Q3 in full: proof-Q1.md, proof-Q2.md, proof-Q3.md.
How it plugs into a drone
- pathfinderd runs on a companion computer beside a stock ArduPilot flight controller (ArduCopter 4.6.3 in our tests).
- It reads HIGHRES_IMU at 200 Hz, SCALED_IMU, ATTITUDE, GPS_RAW_INT, SCALED_PRESSURE over MAVLink.
- It sends ODOMETRY at 20 Hz as EKF3 external nav, or GPS_INPUT as a second GPS.
- config/presets.json: 11 presets, default best. Pick with --preset, PATHFINDER_PRESET or the Control Room Setup picker. Every switch off = byte-identical main. Two more wait on their branches: experimental-terrain and experimental-drift-ai-gated.
- The Control Room at localhost:8790 flies, re-flies, trains, tests, replays and presents.
Integration is shown in the simulator only. No real aircraft has run Pathfinder yet; real flight logs are our next step.
Watch the demo
Flight heldout-jam-1002: the true path and every system's estimate on one map, measured (sim).
- Live: localhost:8790/?present=1 (Control Room, present mode; demo laptop or a PC running the Control Room).
- Recorded fallback: replay-1002.webm. Run-sheet: DEMO.html.
What is inside Pathfinder
The "speed model alone" row is the speed model box on its own. Each box says what goes in and what comes out. The "Pathfinder (physics + speed AI)" row is every box below, running together on the drone.
Today most of Pathfinder's accuracy comes from the motion sensors and the air-resistance model. The speed model counts for little; we have not measured exactly how little. Switching it off made about the same result.
What this means
- Without GPS, today's autopilot gets lost fast: 1.4 km off after one minute, 3.9 km after five.
- Our speed model alone cuts that to about 40%: 1.5 km off after five minutes. Better, but not good enough to fly on.
- With all parts together, the drone stayed within 85 m for five minutes and kept flying its mission. That was one flight in a simulator. The 24-flight tests below decide whether it holds up.
Tests that decide whether it is done
- worksSame answer every time. Results match on Windows and Linux, and replaying a flight gives exactly the same numbers.
- not yetKeeps flying the mission. 20 of 24 test flights finished; 23 are needed. In all 4 failures, the autopilot's own safety check made the drone land.
- not yetSpots fake GPS. The fake signal was caught on all 31 flights. But 26 flights failed the "no sudden jump" check: 21 because the check counts normal movement as a jump, and 5 for a reason already fixed.
- no result yetGives an honest margin of error. The test stopped when the computer's disk filled up. In the 8 flights that finished, the drone was inside its stated margin 99.77% of the time. The upper limit is 98%, so the margin is drawn too wide.
- no result yetDrifts less than the autopilot alone. The test stopped on its first flight when the disk filled up. A re-run is queued.
- not tested yetThree more checks: switching back when GPS returns, settings for other drone types, and how much self-calibration helps. Not yet flown in full.
A framework: position sources plug in
Every source enters the filter the same way: a measurement and its uncertainty. Pathfinder takes care of jam detection, fusion, the error radius, presets, the Control Room and the tests.
- builtPhysics filter and speed AI. On main, flown in the simulator.
- off by defaultDrift-correcting AI. On main, about 6x worse at 2 min, so it stays off.
- on a branchTerrain matching. Offline 200.4 to 128.1 m at 5 min; lost one flight in the air. Branch dnav-terrain.
- plannedVisual-inertial odometry, optical flow, visual SLAM, LiDAR SLAM, image place recognition over a pre-scanned Cyprus. Not built; no results.
Today each source is one fuse call on the filter (crates/pathfinder-core/src/estimator.rs:11). One plug-in interface is planned.
Details and sources
Simulator
Every number is measured in simulation: ArduCopter 4.6.3 in the ArduPilot simulator (SITL). None comes from a real aircraft. Task: DNAV-1 "GPS-denied navigation".
How the rows were measured
- Autopilot alone and speed model alone: medians of 8 held-out jammed flights (flights the model never trained on; quad and octa airframes), GPS jammed at 120 s. Speed model = Velocity Predictor v3. 2026-10-learned-v3-heldout.md
- Pathfinder 3 / 5 / 85 m and same-flight ArduPilot 866 / 1,234 / 2,366 m: flight heldout-jam-1000, 2 of 2 runs identical. 2026-10-12-morning-proof.md
- Same figures as the jury deck: deck-data.json
Names in the code
- Speed model = Velocity Predictor. Speed-model tuner = Predictor Adapter. Drone sensors = IMU (200 Hz), autopilot attitude, barometer, compass, motor outputs, GPS_RAW_INT. Position tracker = Position Estimator (accelerometer, gyro, compass, barometer, drag model; outputs an error radius). Switch = Navigator. GPS checker = GPS Integrity Monitor (Trusted / Suspect / Rejected). Position goes to ArduPilot over MAVLink.
- D-68 "Trust schedule stays off": in the 12 Oct trust on/off runs on this flight, Pathfinder (physics only) was 127-129 m off at 5 minutes and physics + speed AI 132-138 m. 2026-10-12-trust-on-off-matrix.md · Pathfinder method in one page
Test ids
- Acceptance re-run 14 October 16:09-16:40 (main 8343ad0, stopped at the deadline inside AC-01), measured (sim):
- AC-01 "Mission continues": red, 1 pass of 12 flown (needs 95 % of 24); the 11 fails are ArduPilot EKF failsafe to LAND.
- AC-02 "Less drift": not re-run today; last red, 13 October (20.55 vs 20.28 m at 5 min).
- AC-03 "Honest radius": not re-run today; last red, 13 October (99.75 % inside the radius, band 90-98 %).
- AC-04 "Spoofing rejected": not re-run today; last green, 13 October.
- AC-05 "GPS return", AC-06 "Vehicle profile", AC-07 "Calibration helps": not re-run today; locked tests never run.
- AC-08 "Cross-platform core": red today, the Windows (msvc) build and test failed; last green 12 October. AC-09 "Deterministic replay": green today.
- Full table:
docs/night/2026-10-14-day-summary.md, "Acceptance suite vs results".
This page
Source: docs/RESULTS.html on branch night/DNAV-1-pathfinder. The chart uses a log scale.